baikurazov.com
Napoleon on a rearing horse, from Jacques-Louis David’s painting, in dark greyscale almost lost in black; a thin blue ring circles his head.

Arlan Baikurazov

Robotics engineer

I teach robots to understand a place, move through it, and do useful work for the people in it.

Watch the projects Download CV

“Napoleon Crossing the Alps”

Projects

Seven recordings. Press play to see the footage.

Isaac-L2F quadrotor

Plate I. [0:13, silent]

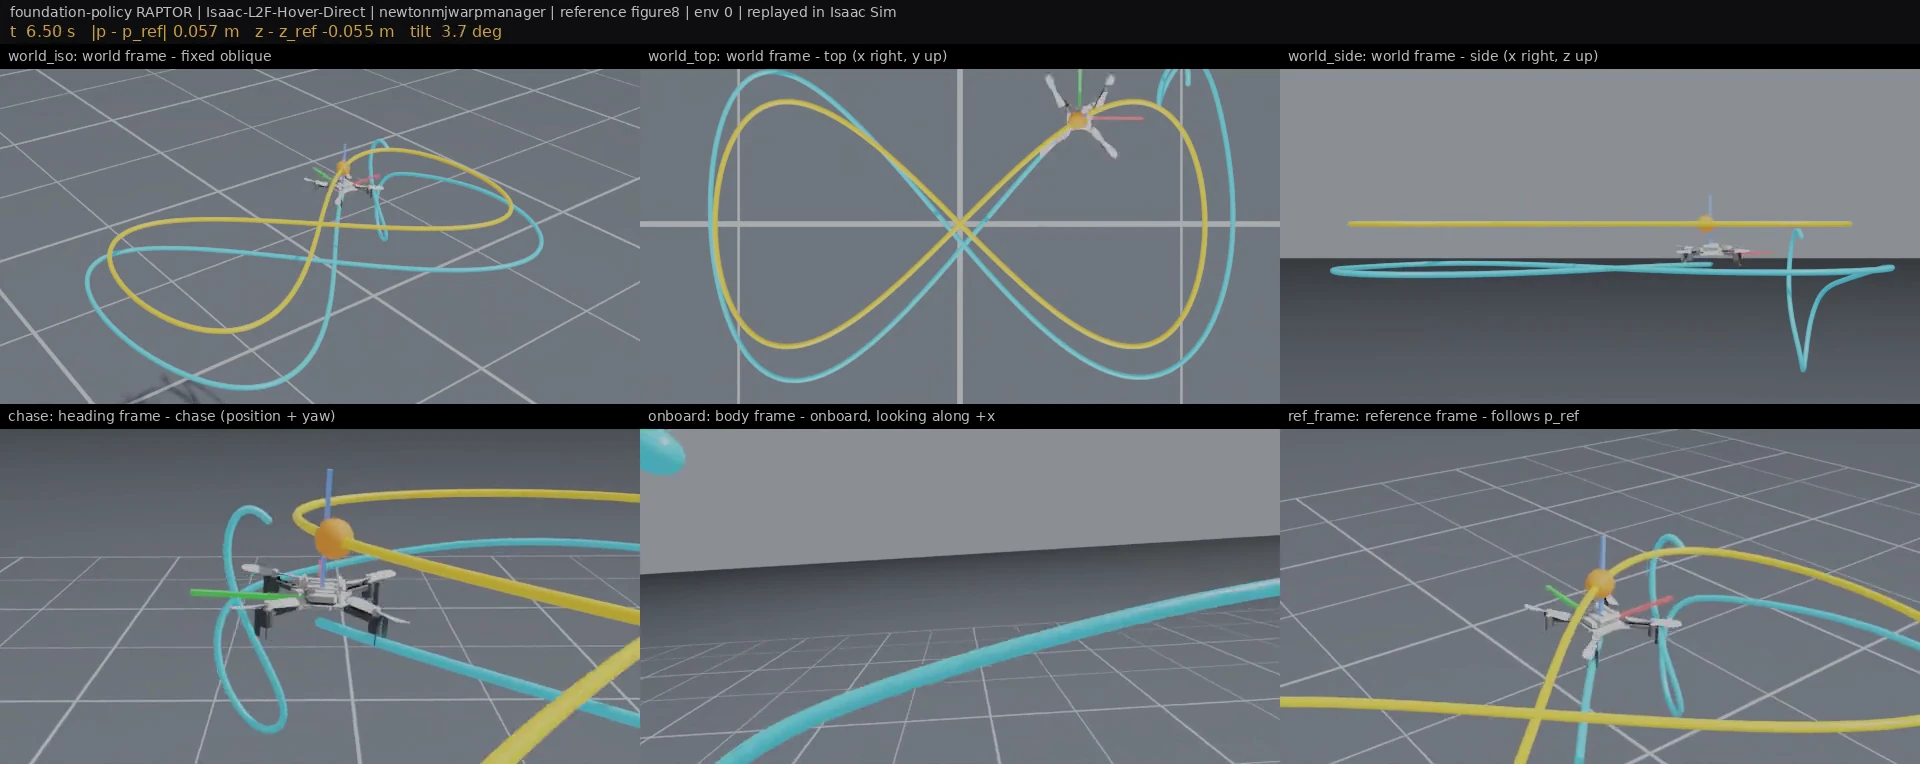
The RAPTOR foundation policy flies a figure-eight in Isaac Lab, without retraining.

Isaac-L2F brings the quadrotor model of L2F (“Learning to Fly in Seconds”) into Isaac Lab 3.0, on Newton and PhysX, so policies trained in L2F fly in Isaac Lab as they are and vision policies can be trained on the same dynamics.

The flight runs on Newton and is replayed in Isaac Sim from six cameras. Yellow is the reference, cyan the path flown.
Code on GitHub

Go2 building inspection

Plate II. [3:22, sound]

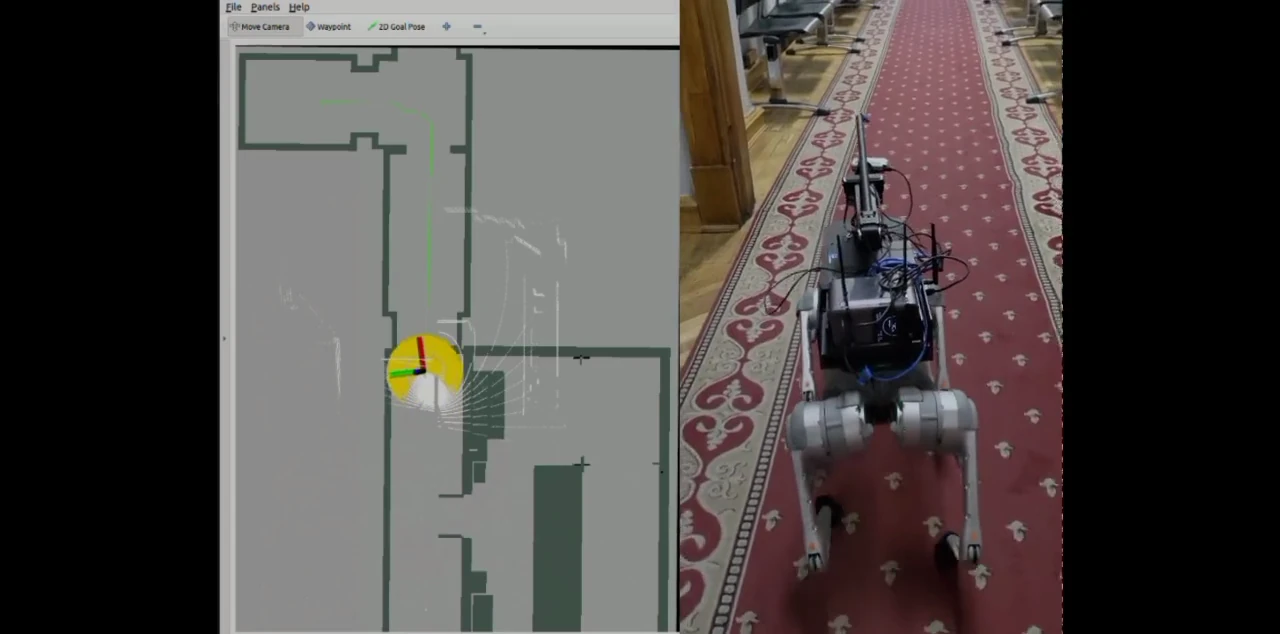
A Unitree Go2 quadruped inspects a building on its own.

Inspection points are chosen in a web interface. The robot orders them from nearest to farthest and plans a path.

It checks ceiling lights (working, or only half working), confirms a fire extinguisher is in place, and looks for cracks in a wall.

Then it calls the lift:

  1. aligns itself to an AprilTag
  2. presses the call button with a rod on a small servo arm
  3. docks inside
  4. presses the floor button
  5. exits on the destination floor

A report is generated in the web interface and can be saved as PDF.

G1 control from a phone

Plate III. [2:26, sound]

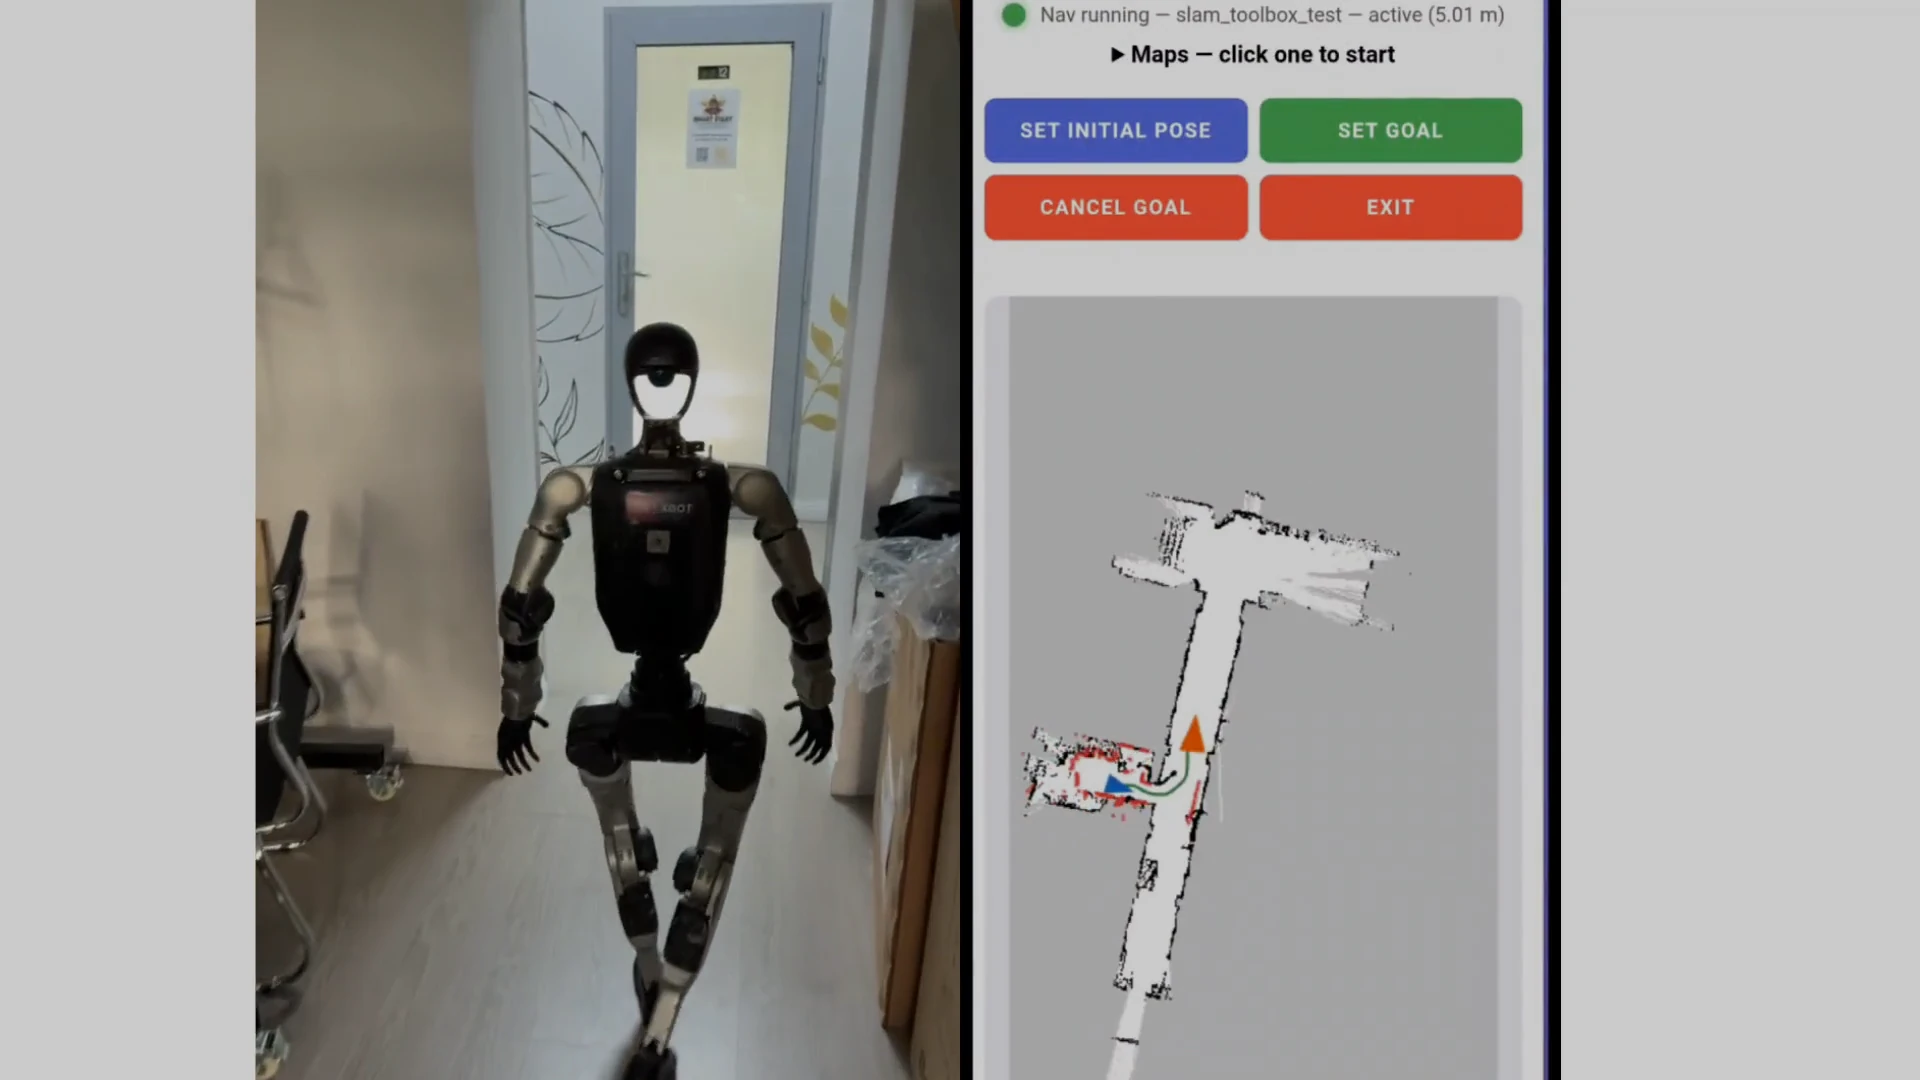
A web app for the Unitree G1 humanoid, used from a phone.

Start SLAM with slam_toolbox and watch the occupancy map grow live while the robot walks. Save the map, then localise on a saved map and send the robot to goals.

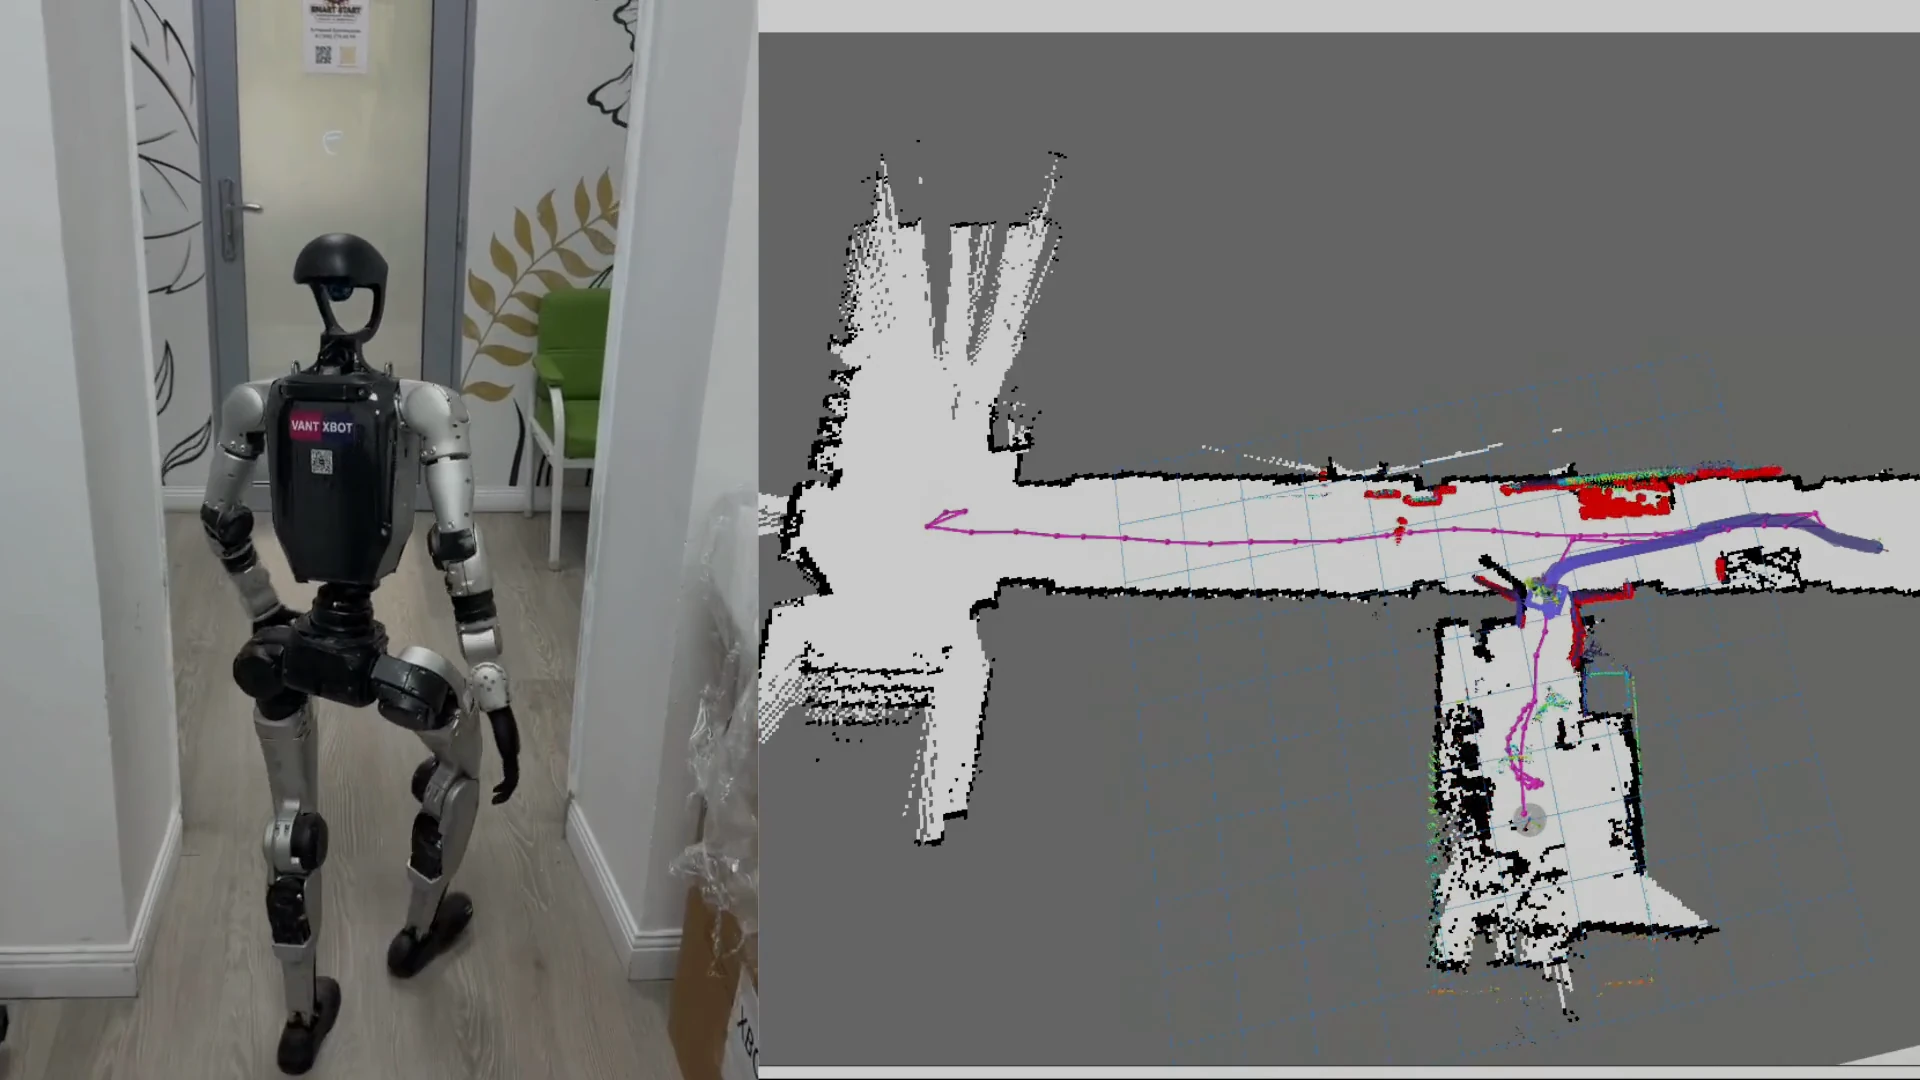
G1 map-based navigation

Plate IV. [1:26, sound]

The G1 walks from a room, along a corridor and into a lobby, following a planned path.

The occupancy-grid map and the path are shown beside the footage.

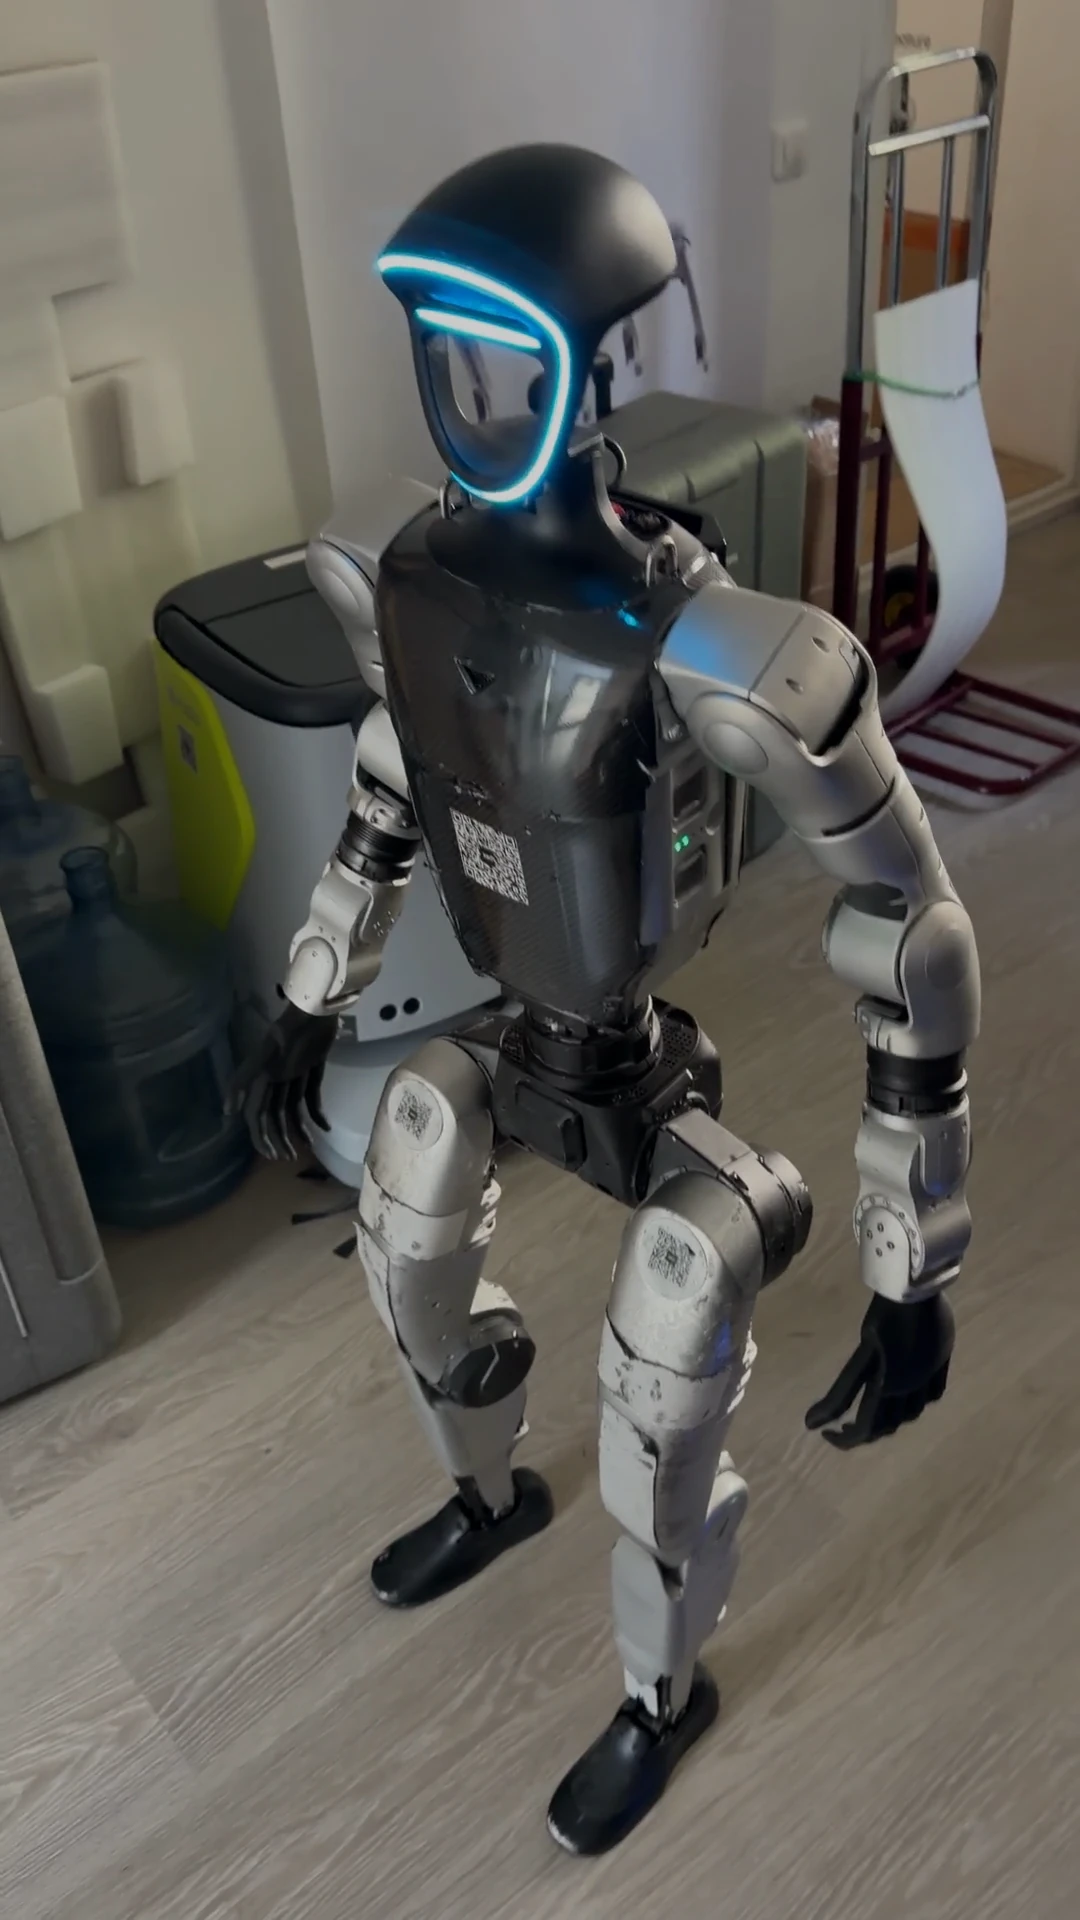
G1 voice control

Plate V. [1:34, sound]

The G1 takes spoken commands.

It raises an arm, then walks out of the room, down the corridor and back.

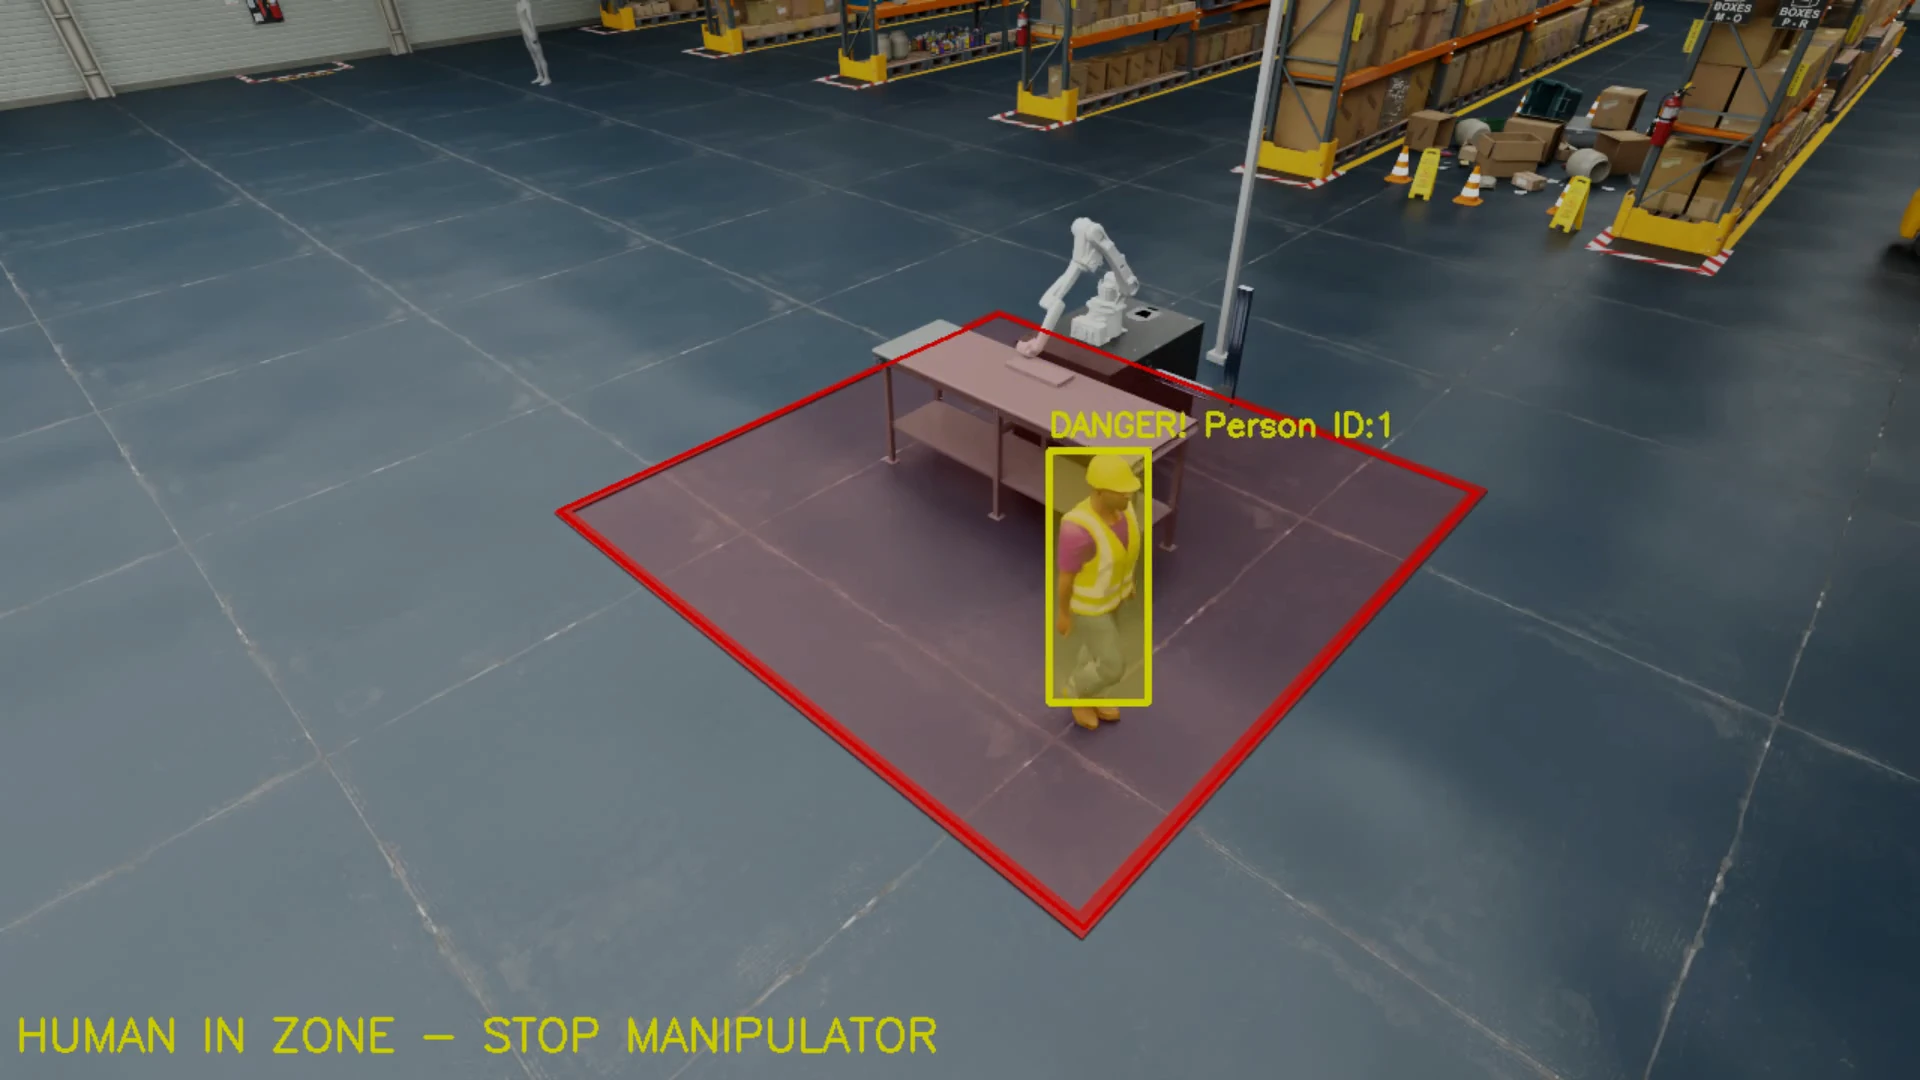
Safety zone in Isaac Sim

Plate VI. [0:49, silent]

A simulated warehouse with a marked zone around a manipulator.

When a detected person steps into the zone, the system raises “HUMAN IN ZONE — STOP MANIPULATOR”, and returns to “Zone: CLEAR” when they leave.

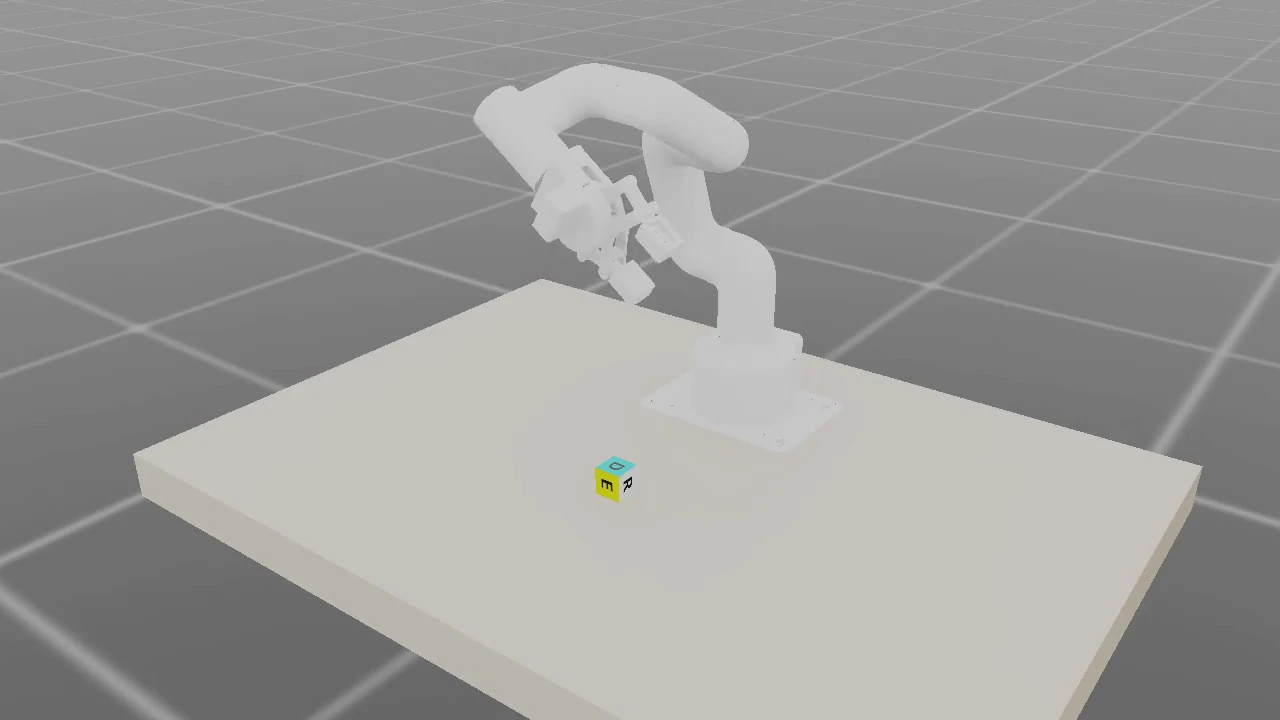
Pick-up policy

Plate VII. [0:05, silent]

A reinforcement-learning policy picks a cube up off a table in simulation.

About

My work is making legged robots autonomous in real environments: building maps, navigating to goals, inspecting infrastructure, and picking things up. I train policies in simulation and bring them to Unitree G1 and Go2 hardware.

From February to May 2026 I worked as a robotics engineer at XBOT, the authorised Unitree Robotics distributor in Almaty.

Download CV

Experience

  1. 2026 – Robotics Engineer, Circle
    A voice-assistant device on ESP32 and ESP-IDF: a HUB75 LED-matrix face driver written from scratch, full-duplex I2S audio over TCP, on-device wake word, and a Claude-based speech pipeline. Enclosure and single-supply power design.
  2. 2026 Robotics Engineer, XBOT
    SLAM navigation on Unitree robots in ROS 2, and a voice agent with local LLM, speech and wake word on Jetson Orin NX.
  3. 2025 – 26 Machine Learning Engineer, Avto-time
    Licence-plate recognition from RTSP cameras with YOLO and OCR, logged to PostgreSQL.
  4. 2025 Go2 inspection researcher, KBTU
    Autonomous building inspection with YOLOv11, indoor localisation and planning, and elevator use with an arm on the quadruped.
  5. 2025 Quadruped hackathon, Astana
    First place: SLAM navigation and a web control interface over a custom ROS 2 bridge.
  6. 2024 – 25 Machine Learning Engineer, Doro AI
    Fine-tuned vision models and GANs, served with FastAPI. Google for Startups participant.

BEng Robotics and Mechatronics, Kazakh-British Technical University, 2022 – 2027.

Tools: ROS 2, Isaac Sim and Isaac Lab, PyTorch, OpenCV, Python, C++, Docker, NVIDIA Jetson.

Contact